High Speed Tracking
Autonomous High-Velocity
Autonomous High-Velocity
Drone Tracking System
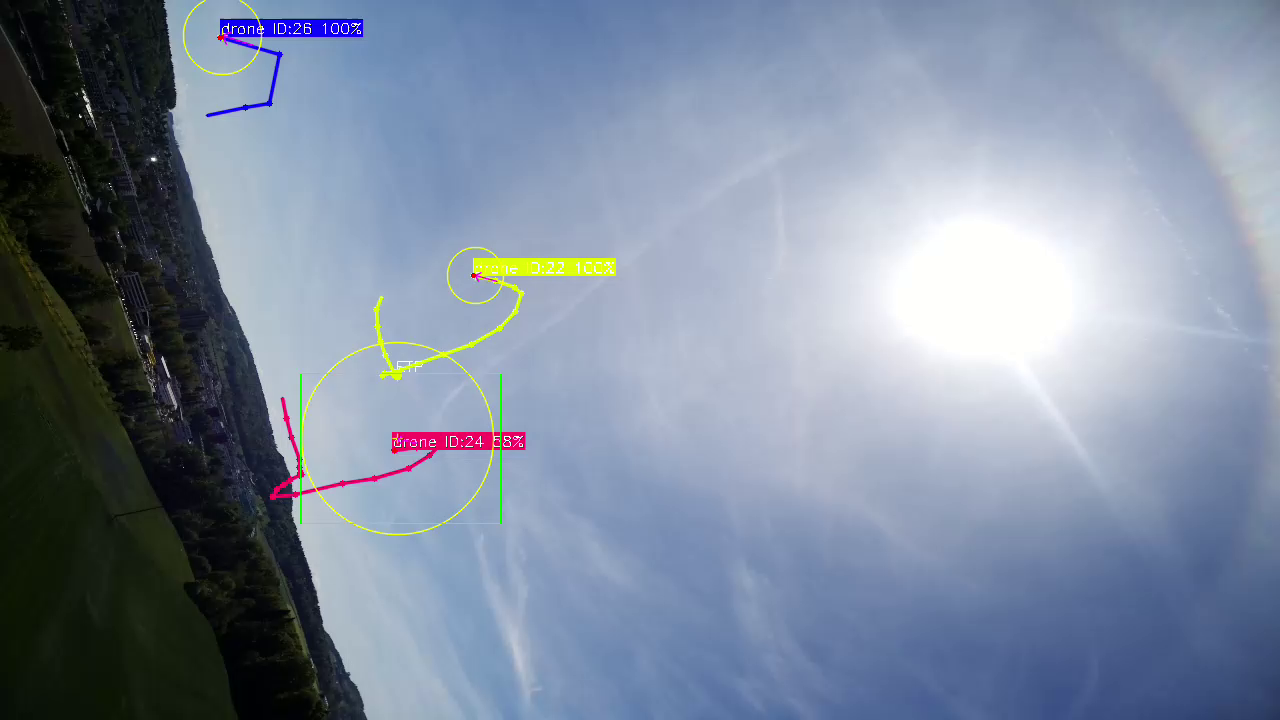
Development of a localized, real-time tracking system utilizing low-latency GPU acceleration for the identification and trajectory prediction of high-speed aerial objects on edge hardware. The system operates fully offline, eliminating cloud dependency and achieving deterministic sub-millisecond response times in dynamic, uncontrolled environments.
Key Pillars
- Edge GPU Acceleration (NVIDIA Jetson / TensorRT)
- High-Frequency Inference Pipeline
- Tensor-based Parallel Image Preprocessing
- Kalman Filter Trajectory Prediction
- Custom Object Detection Model Fine-tuning
Business Value
- Zero-latency response via on-device processing
- Bandwidth optimization through edge analytics
- Resilient operation in disconnected environments
- Scalable to multi-camera deployments